Bionic Sensing with Artificial Lateral Line Systems for Fish-Like Underwater Robots
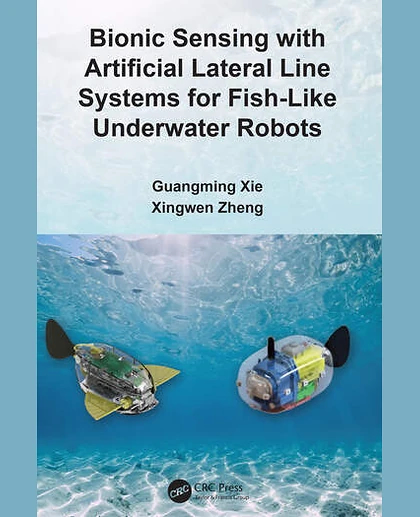
Bionic Sensing with Artificial Lateral Line Systems for Fish-Like Underwater Robots
Summary
In this book, the authors first introduce two fish-like underwater robots, including a multiple fins-actuated robotic fish and a caudal fin-actuated robotic fish with a barycenter regulating mechanism. They study how a robotic fish uses its onboard pressure sensor arrays based-ALLS to estimate its trajectory in multiple locomotions, including rectilinear motion, turning motion, ascending motion, and spiral motion. In addition, they also explore the ALLS-based relative position and attitude perception between two robotic fish in a leader-follower formation. Four regression methods—multiple linear regression methods, support vector regressions, back propagation neural networks, and random forest methods—are used to evaluate the relative positions or attitudes using the ALLS data.
The research on ALLS-based local sensing between two adjacent fish robots extends current research from one individual underwater robot to two robots in formation, and will attract increasing attention from scholars of robotics, underwater technology, biomechanics and systems, and control engineering.